Start with a real task.
Usefulness comes before spectacle. A robot earns complexity by reducing real friction for a person or field operation.
 Monkdroid
field
monkdroid.com · humanophilic robotics
Repairable. Overrideable. Built for the field.
hAIr — Human AI Resource: AI and robotics as a resource for extending human capabilities. People guide and decide; technology perceives, helps and acts within clear boundaries. Monkdroid is the path towards that goal — through software, MonkBox and the development of an assistant robot.
Serbia’s first autonomous robot factory — in the making.
We’ve only just begun.
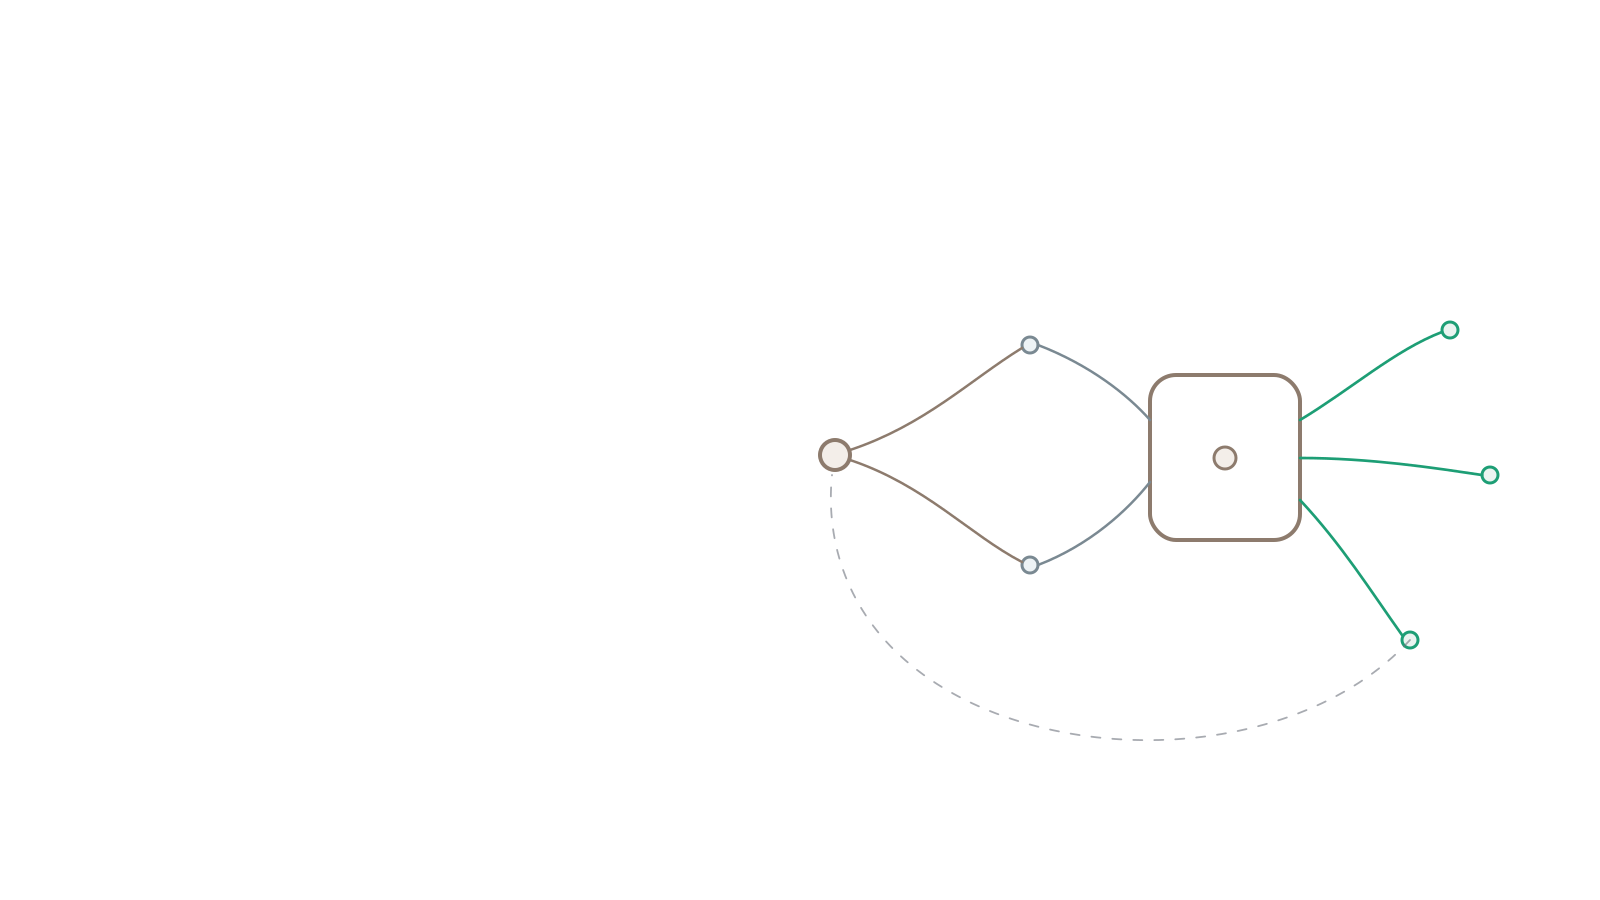
INTENT → SENSE → ACT → FEEDBACK → OVERRIDE
Enter the fieldMonkdroid begins with real field needs rather than the demand to imitate a person. A useful robot may carry, observe, communicate, stabilize, or assist without needing a theatrical face or a perfect human silhouette.
Its architecture separates fast balance and safety reflexes from slower perception, dialogue, and planning. Human override, clear operating limits, offline capability, and repairable components are treated as foundations rather than optional features.
The longer-term direction includes adapting capable second-life robotic platforms for assistive use. Every implementation must pass through supervised testing and be shaped with the people who will rely on it.
What is the simplest machine that can return meaningful autonomy to a person?
Build for the field. Keep the human in command. Repair before replacing.
Custom development · Optimization · R&D
Custom software development, code optimization, and research into practical applications in robotics. We are open to conversation, collaboration, and arranging a demo. Let's start with what you want to make possible.
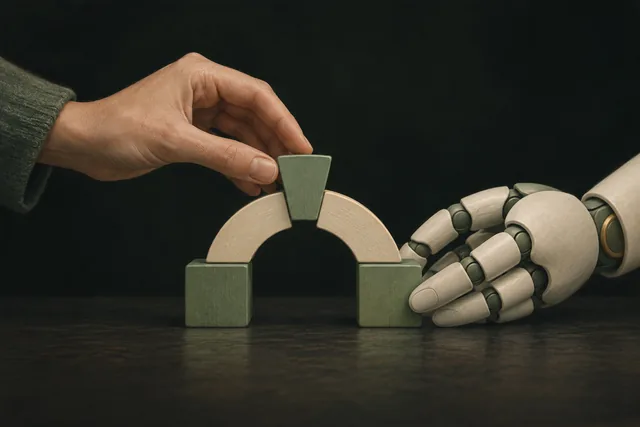
Software, control, and connected systems built around a concrete need. From one missing function to new possibilities for your work.
Restructuring and optimizing existing code into a clear, modular whole. Easier maintenance, more efficient operation, and a steadier path forward.
Exploring possibilities, building prototypes, and demonstrating results. Together, we choose a concrete first step and an outcome worth testing.
Bring an idea, a challenge, or code that has outgrown its original shape.
Useful autonomy
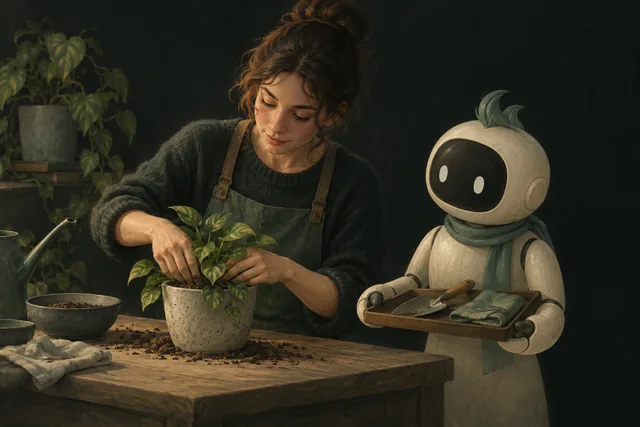
The goal is not to make a machine look independent. The goal is for it to sense, assist and act within clear limits, while the person retains decision-making, direction, feedback and a practical path to the goal. This relationship is called Tango in Semonika, whose principles underpin our technology.
Usefulness comes before spectacle. A robot earns complexity by reducing real friction for a person or field operation.
Modular, understandable systems can be maintained, replaced in parts and returned to service instead of becoming sealed waste.
Autonomy stays bounded by observable state, feedback and the ability to interrupt or redirect the machine when context changes.
Balance and safety reflexes belong close to the machine; slower perception, dialogue and planning stay inside visible operating limits. Low speed, low force and a physical stop come first.
Mobility, manipulation, sensing and power are selected for work such as environmental sampling, tool transport and inspection of hard-to-reach infrastructure — not for a theatrical silhouette.
Supervision and teleoperation preserve a clear handoff when certainty falls. A useful robot can act, ask, wait or return authority with context intact.
Monkdroid is the applied robotics edge of the field: local-first where practical, repairable by design, and oriented toward assistance rather than performance theatre.
These questions already appear across humanoid robotics, service and assistive robotics, field robotics, human–robot interaction, robot safety, embodied AI and the right to repair. Monkdroid connects them through a practical rule: use the least complex machine that can safely serve the real task while keeping human command, feedback and recovery open.
Bounded autonomy
Bikasha · Monkdroid field log